Articulated manipulation
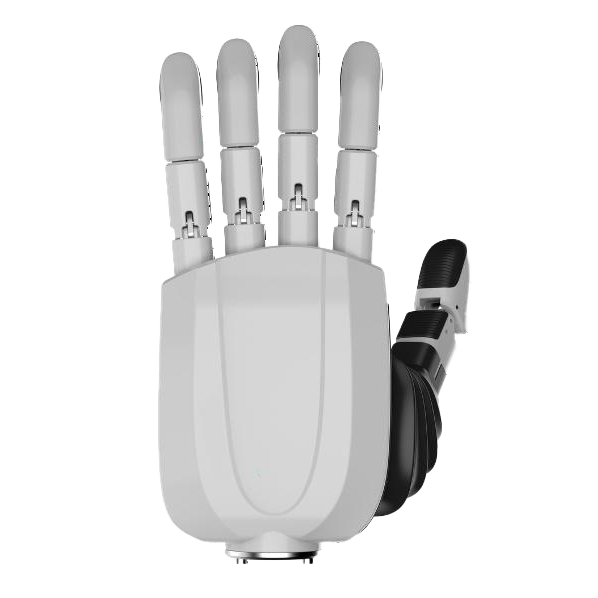
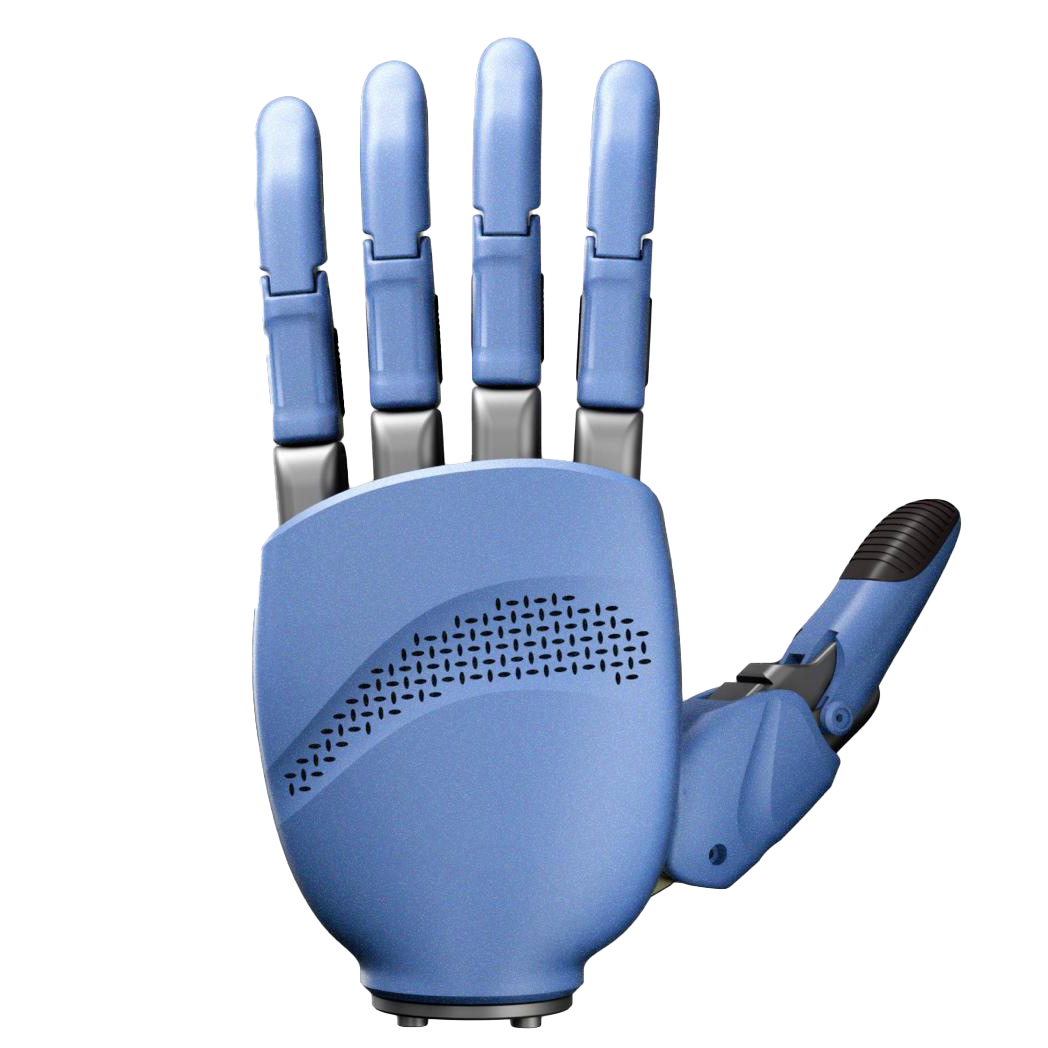
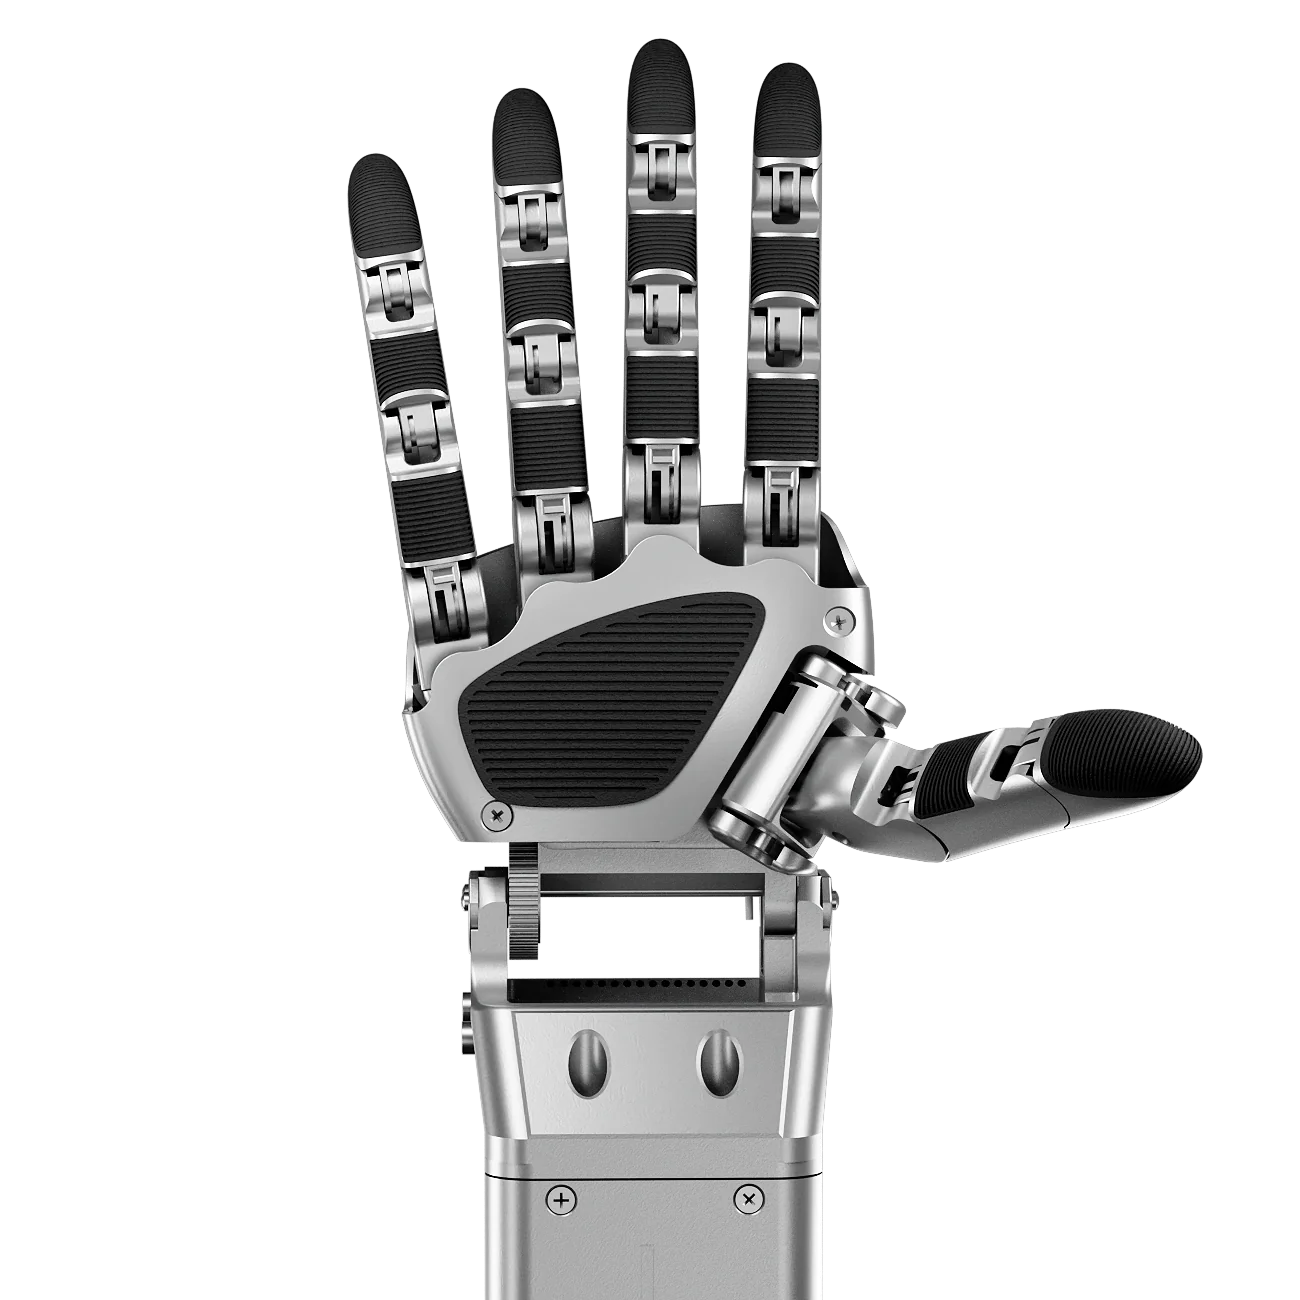
21 joints combine 16 active and 5 passive joints. Four-finger abduction provides +/-10 degrees of side swing.
Dexterous Hand
A high-DOF dexterous hand with 16 active and 5 passive joints, 100 N five-finger grip force, and tactile sensing options for advanced manipulation.
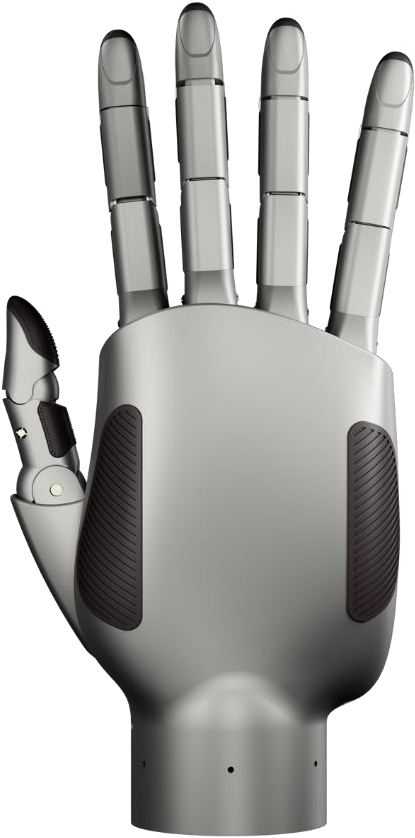 L20 / Dexterous Hand
Designed for the task
21 joints combine 16 active and 5 passive joints. Four-finger abduction provides +/-10 degrees of side swing.
100 N five-finger grip force, a 10 kg maximum load, and +/-0.2 mm repeat positioning accuracy.
A 6x12 pressure array, with optional capacitive 3D force, camera, and visual-tactile sensing.
The details
Product information and specifications from RealHand.
| Degrees of Freedom | 16 DoF, 21 joints (16 active + 5 passive) |
|---|---|
| Four-finger Abduction | +/-10 deg side swing |
| Five-finger Grip Force | 100 N |
| Fingertip Force (Thumb / Four Fingers) | 18 N / 20 N |
| Weight | 1100 g |
| Maximum Load | 10 kg |
| Opening / Closing Time | 1.2 s |
| Repeat Positioning Accuracy | +/-0.2 mm |
| Control Interface | CAN / RS485, 600 kHz |
| Operating Voltage | 24 V +/-10% |
| Tactile Sensing | 6x12 pressure array; capacitive 3D force, cameras, and visual-tactile optional |
A closer look
The connected ecosystem
Build with us
Talk to our team about your application, hardware, or robotics workflow.
Talk to our teamsales@realworldlabs.com