Compact integration
A 618.5 g hand with a 24 V DC power supply, CAN 2.0 communication, and an ISO 9409-1-50-4-M6 wrist flange.
Dexterous Hand
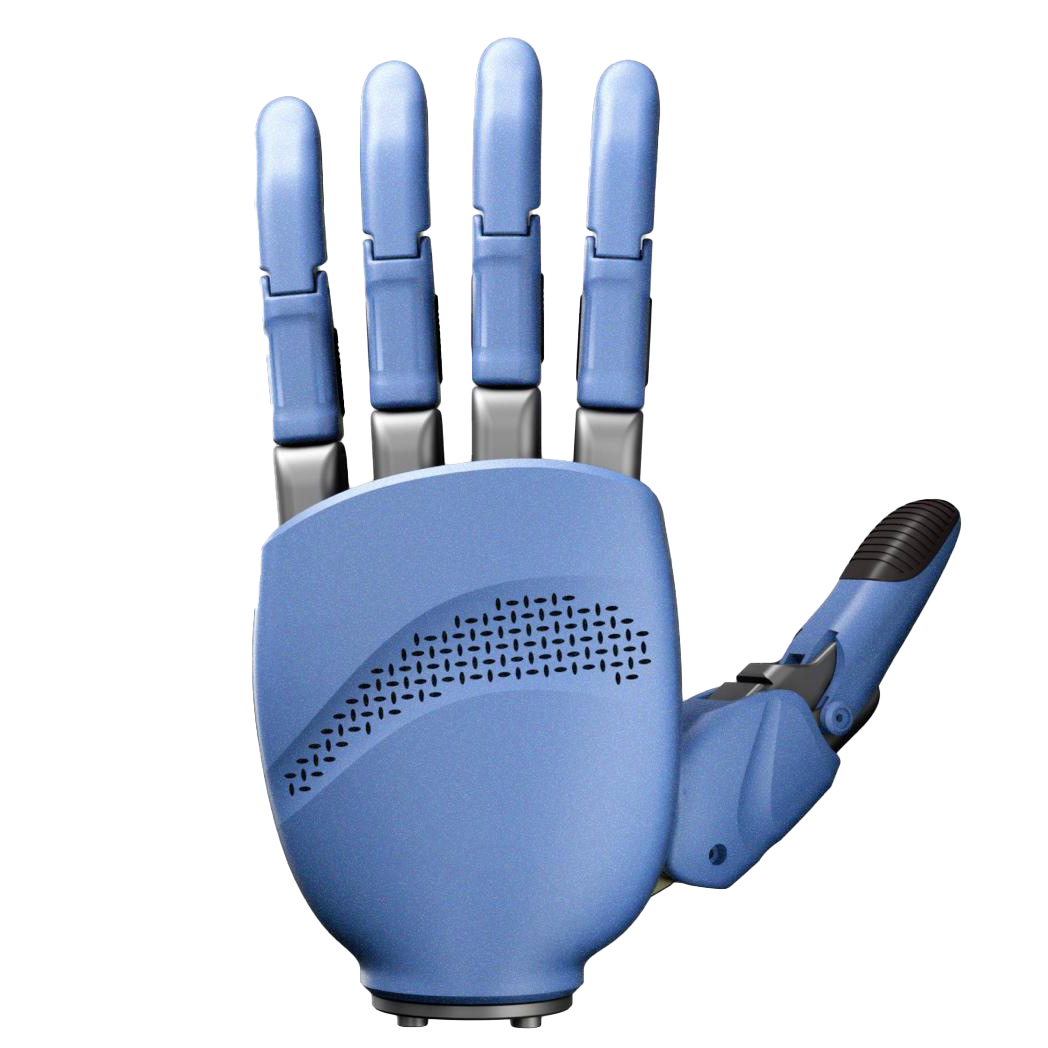
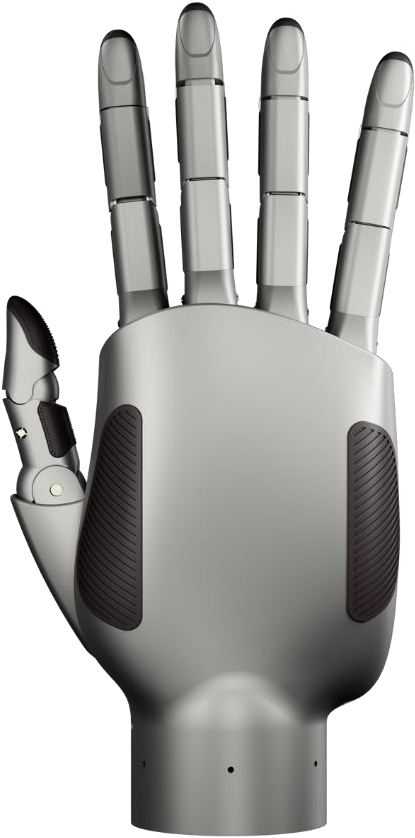
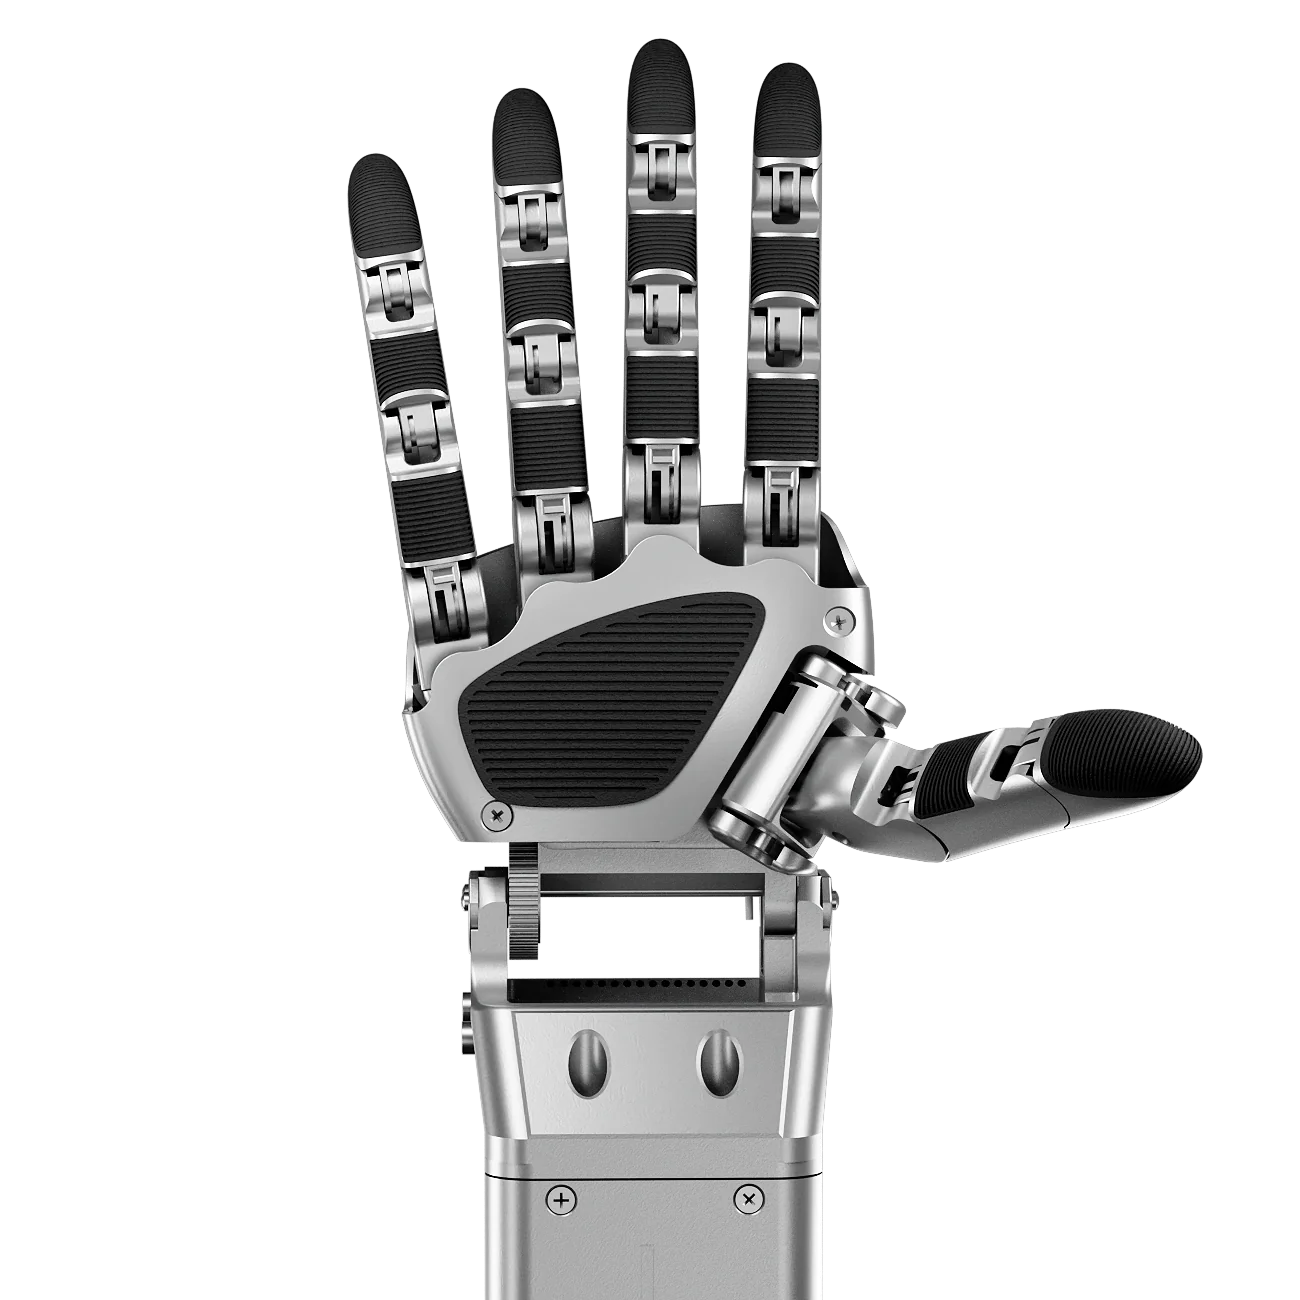
A compact, power-efficient dexterous hand with 6 active and 5 passive degrees of freedom, designed for embedded systems and scaled deployments.
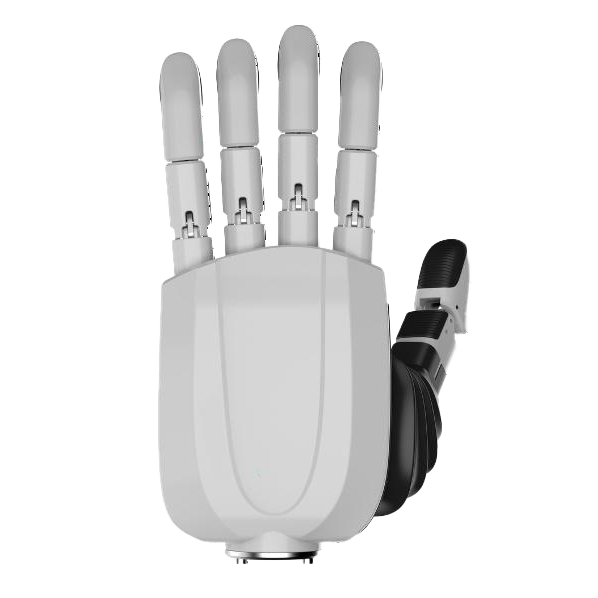 L6 / Dexterous Hand
Designed for the task
A 618.5 g hand with a 24 V DC power supply, CAN 2.0 communication, and an ISO 9409-1-50-4-M6 wrist flange.
Active joints operate at 180 deg/s, with a 0.35-second opening/closing response and +/-0.2 mm repeat positioning accuracy.
Passive joints follow their corresponding active joints through mechanical coupling, supporting natural grasping motions.
The details
Product information and specifications from RealHand.
| Model | Realhand L6 |
|---|---|
| Weight | 618.5 g |
| Total Degrees of Freedom | 11 (6 active + 5 passive) |
| Active Joints | 6 |
| Passive Joints | 5 |
| Repeat Positioning Accuracy | +/-0.2 mm |
| Opening/Closing Response Time | 0.35 seconds |
| Joint Movement Speed | 180 deg/s (active joints) |
| Maximum Grip Force | TBD (contact for specifications) |
| Power Supply | 24V DC |
| Communication Protocol | CAN 2.0 |
| Operating Temperature | 0 C ~ 40 C |
| Storage Temperature | -20 C ~ 60 C |
| Wrist Flange | ISO 9409-1-50-4-M6 standard |
| Middle fingertip to palm base | 183 mm |
| Maximum palm width | 106 mm |
| Thumb tip to palm base | 105 mm |
| Wrist height | 76 mm |
| Wrist diameter | 64 mm |
A closer look
The connected ecosystem
Build with us
Talk to our team about your application, hardware, or robotics workflow.
Talk to our teamsales@realworldlabs.com