Strong gripping
A high-torque servo and worm gear drive deliver efficient, rigid gripping.
Dexterous Hand
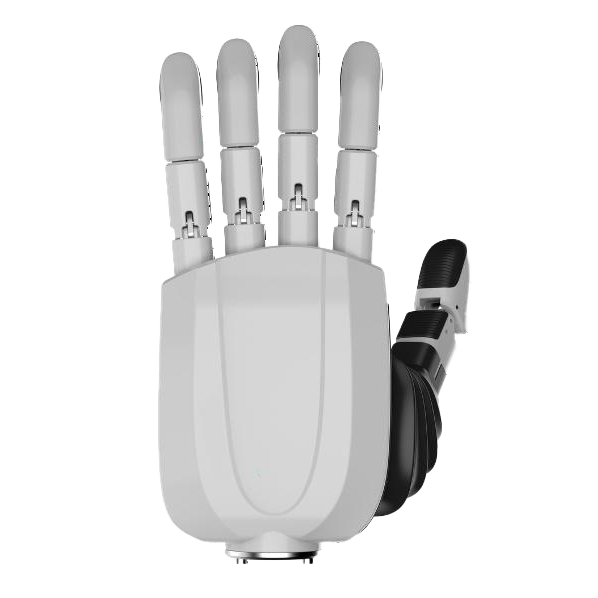
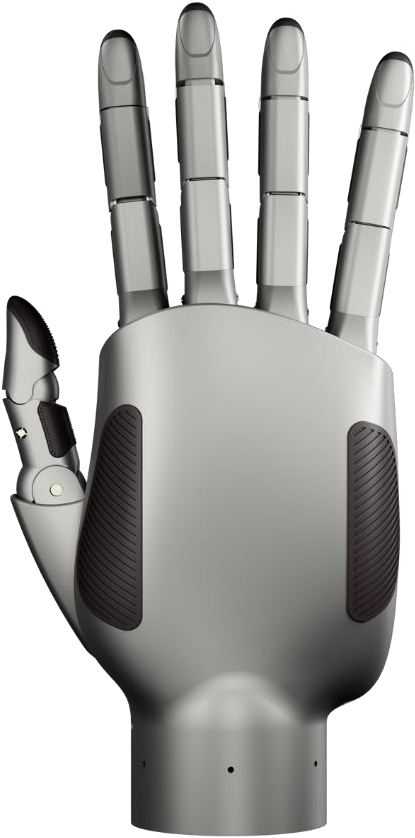
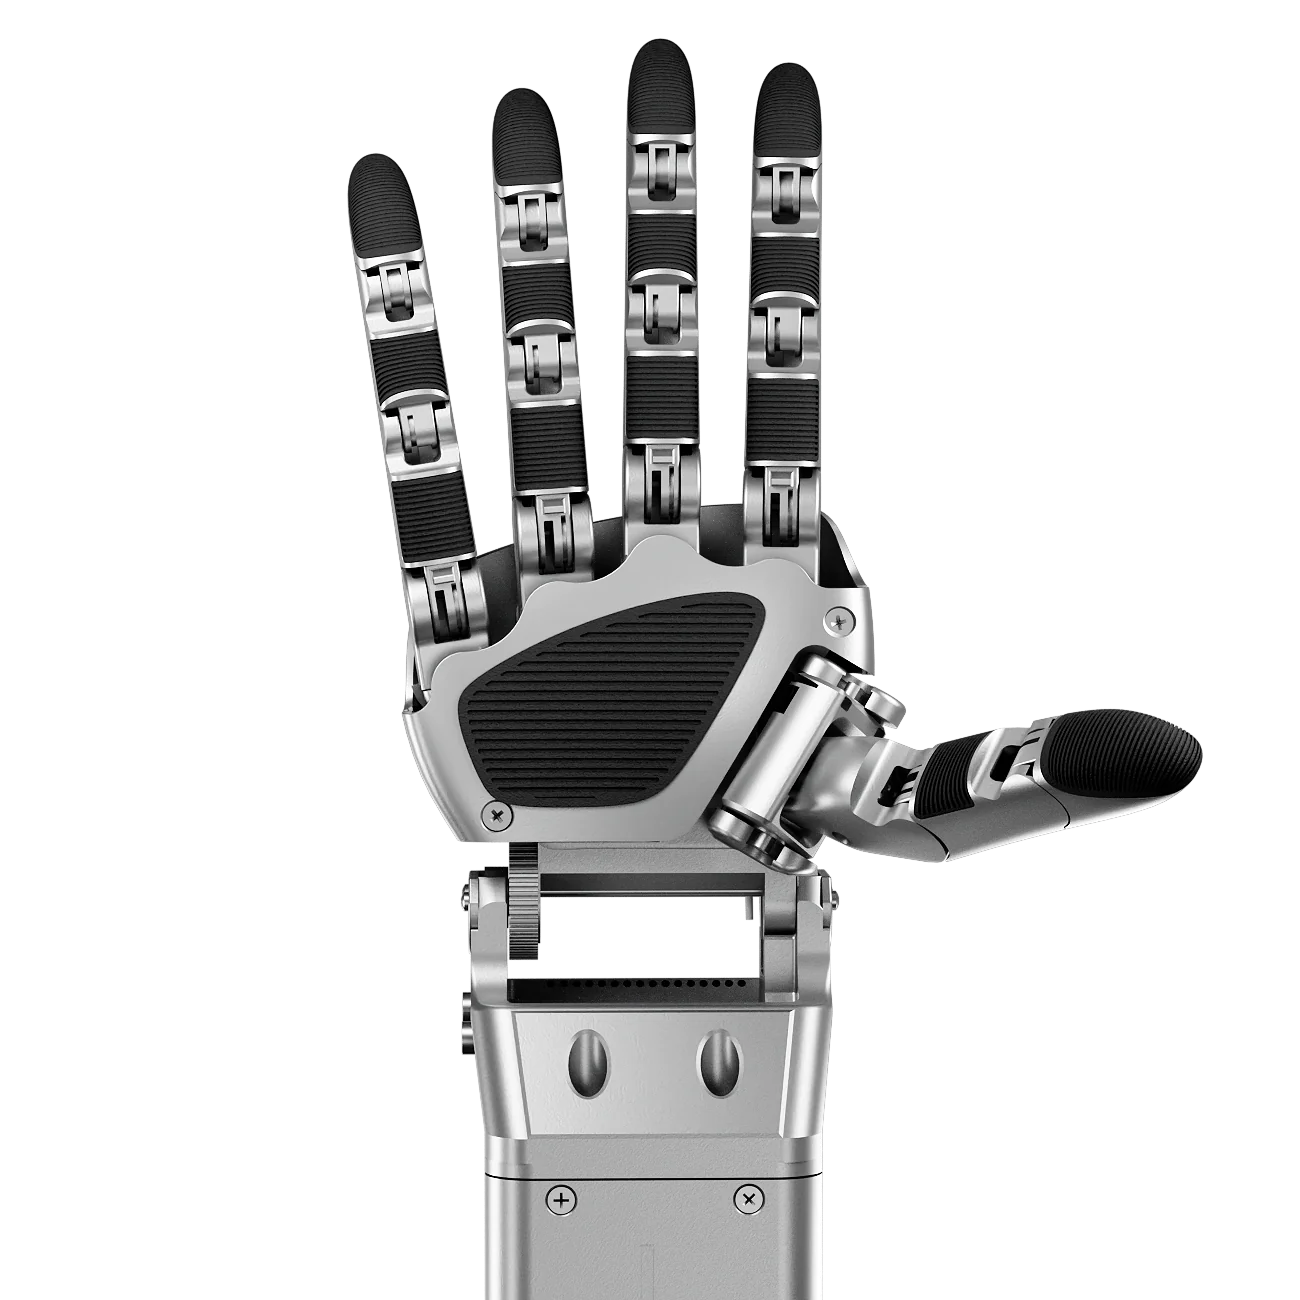
A high-precision bionic hand with 6 active and 5 passive joints, combining strong gripping, precise control, and a compact, lightweight build for logistics, assembly, and irregular-object handling.
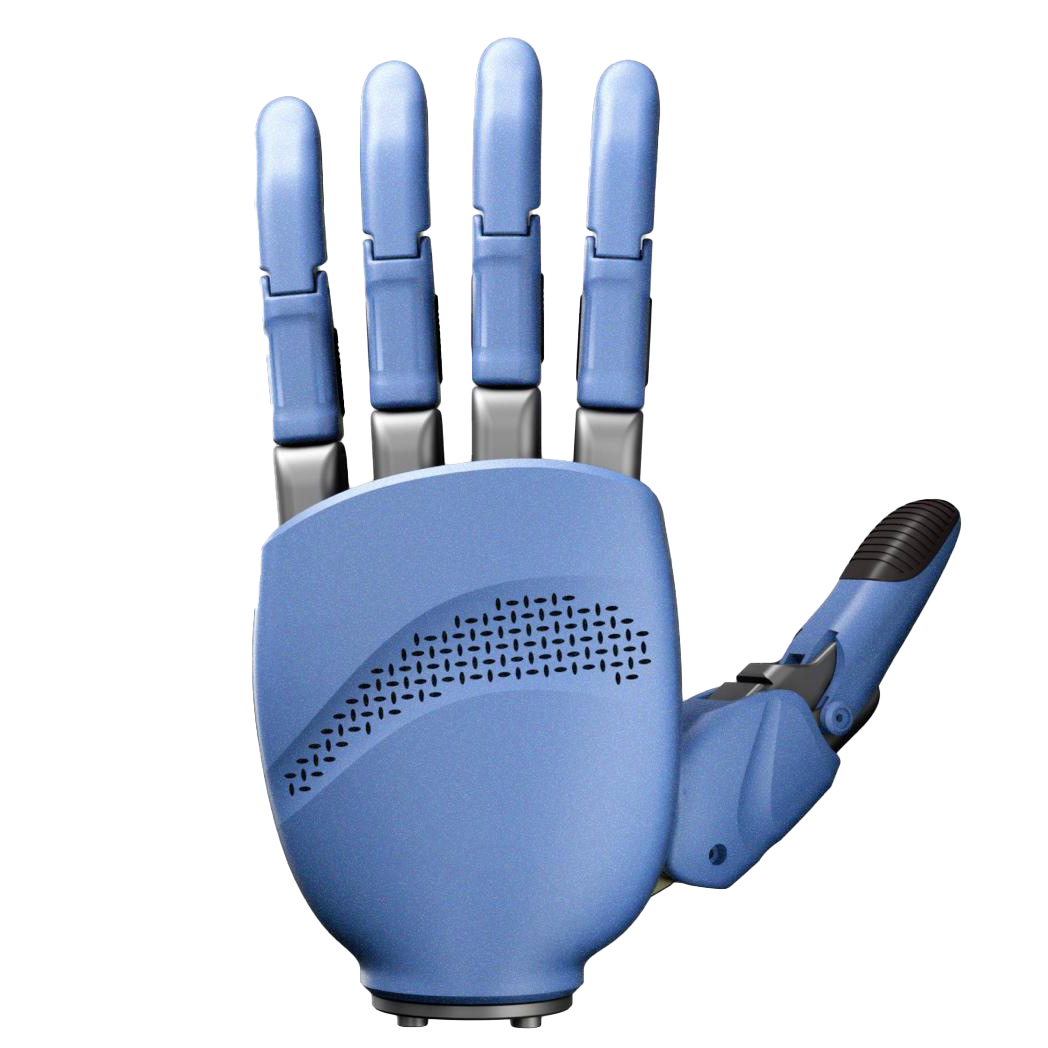 O6 / Dexterous Hand
Designed for the task
A high-torque servo and worm gear drive deliver efficient, rigid gripping.
Rigid-linkage transmission and a hybrid force-position algorithm achieve +/-0.2 mm repeat accuracy.
A 370 g design with an integrated drive-control module and dimensions matched to the human hand.
The details
Product information and specifications from RealHand.
| Degrees of Freedom | 11 (6 Active + 5 Passive DoF) |
|---|---|
| Transmission Method | Linkage Drive |
| Drive Method | Self-Developed Joint Module |
| Control Interface | CAN/RS485 |
| Weight | 370 g |
| Max Payload | 50 kg |
| Working Voltage | DC24V +/-10% |
| Static Current | 0.1 A |
| Average No-load Operating Current | 0.4 A |
| Max Current | 3 A |
| Repeatability | <= 0.20 mm |
| Max Thumb Force | 28 N |
| Max Four Finger Tip Force | 33 N |
| Four Finger Flex Angle | 1.61 rad (92.59 deg) |
| Thumb Lateral Swing Speed | 1.36 rad/s (78.10 deg/s) |
| Thumb Flex Speed | 2.60 rad/s (149.22 deg/s) |
A closer look
The connected ecosystem
Build with us
Talk to our team about your application, hardware, or robotics workflow.
Talk to our teamsales@realworldlabs.com