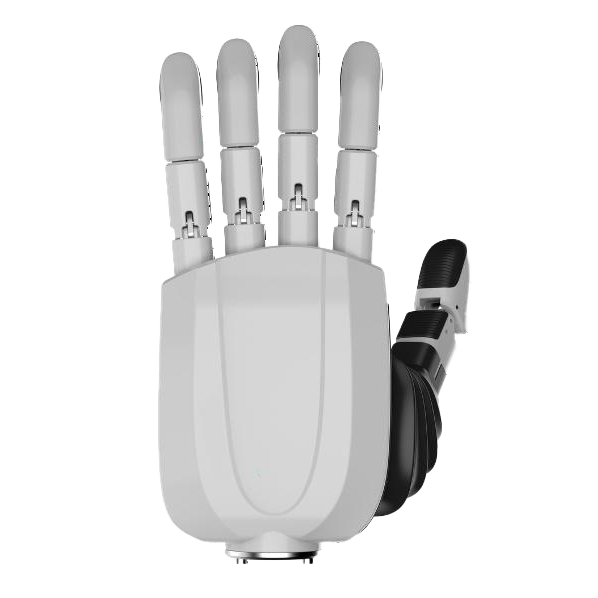
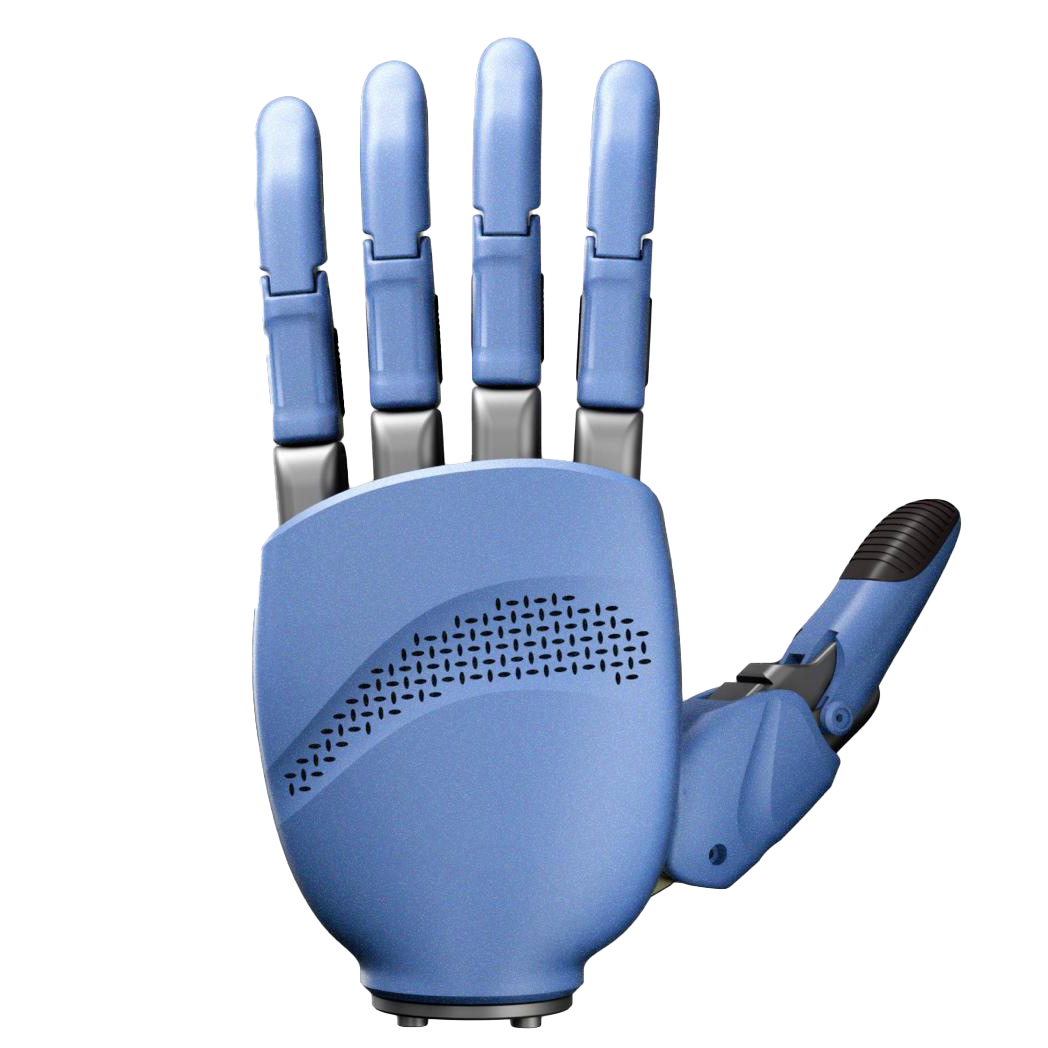
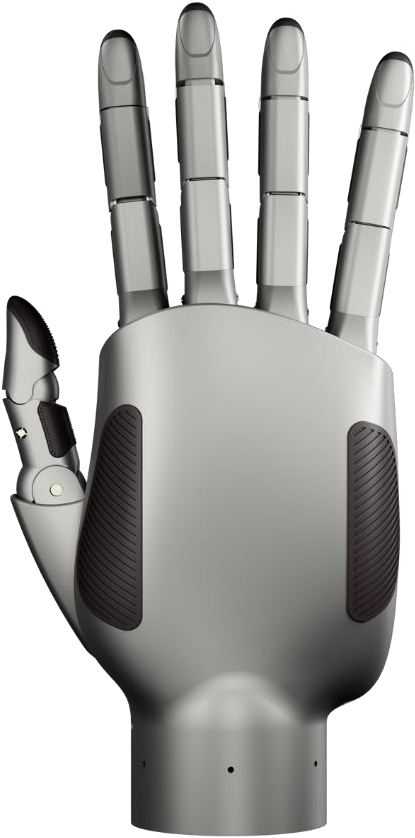
Tendon-driven articulation
17 active and 4 passive degrees of freedom provide articulated control through a tendon-drive transmission.
Dexterous Hand
A tendon-driven dexterous hand with 17 active and 4 passive degrees of freedom, built for responsive manipulation and precise control.
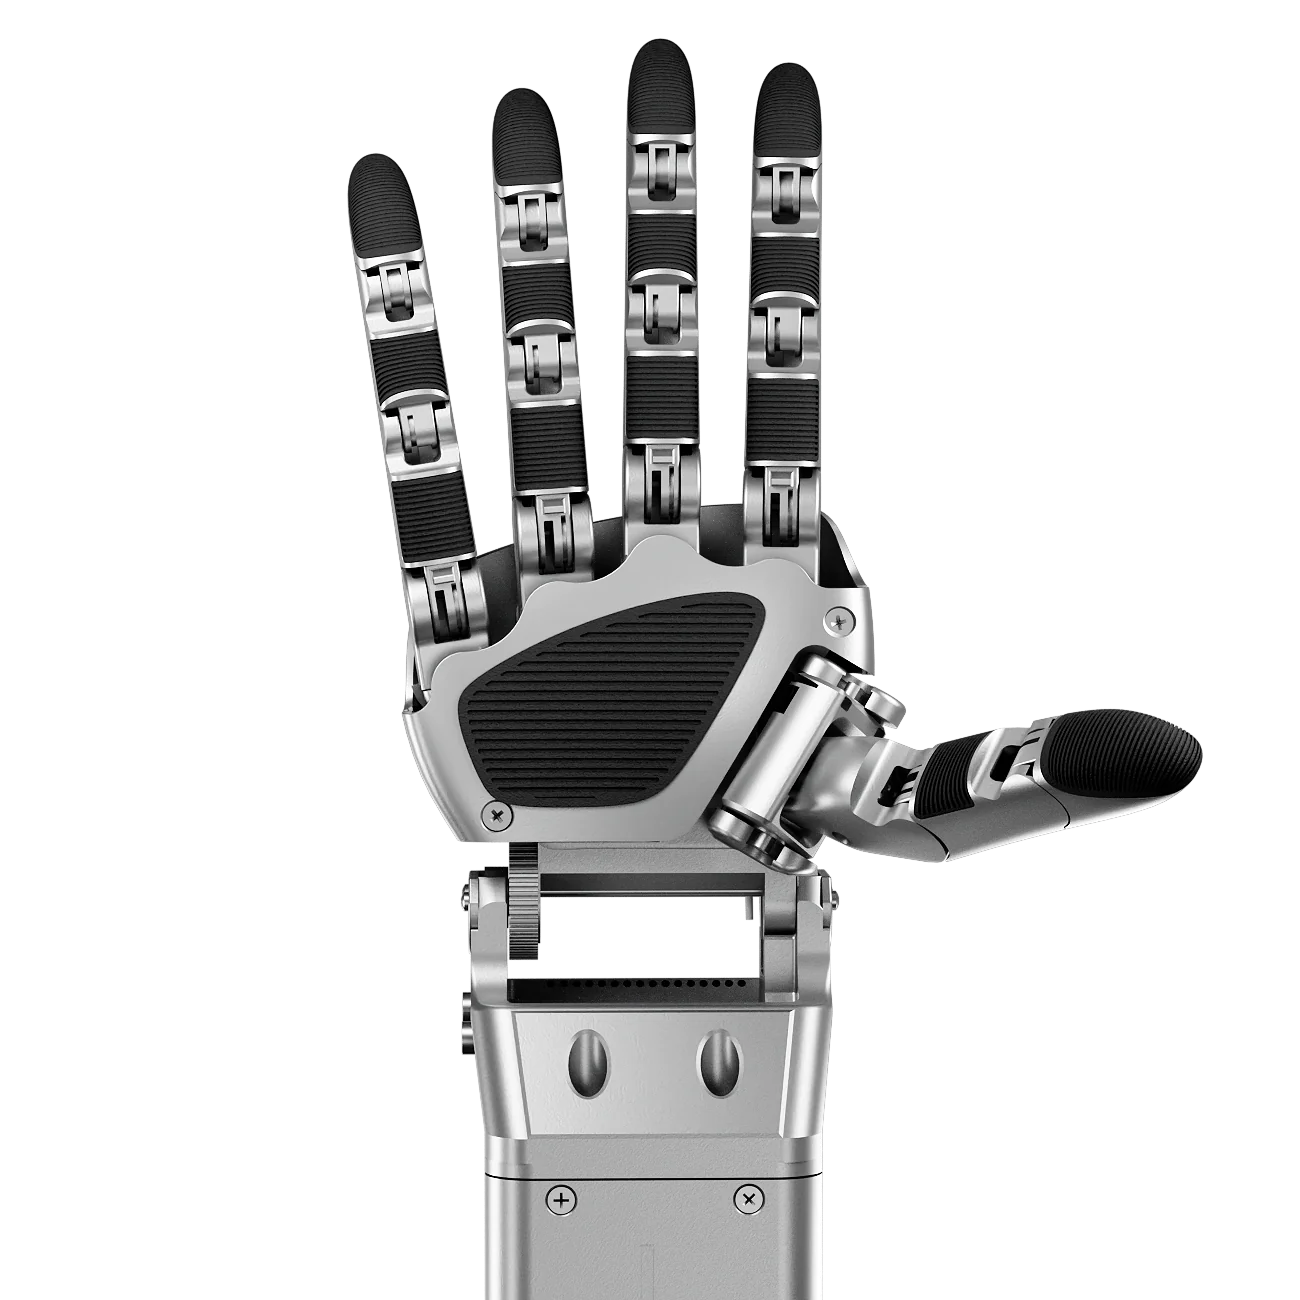 L30 / Dexterous Hand
Designed for the task
17 active and 4 passive degrees of freedom provide articulated control through a tendon-drive transmission.
A 0.2-second opening/closing time and CAN FD communication at 900 Hz support responsive operation.
+/-0.2 mm repeat positioning accuracy and a fingertip tactile sensor array support precise interaction.
The details
Product information and specifications from RealHand.
| Degrees of Freedom | 17 active + 4 passive |
|---|---|
| Transmission | Tendon drive |
| Control Interface | CAN FD |
| Communication Frequency | 900 Hz |
| Weight | Approx. 1,200 g |
| Maximum Load | 15 kg |
| Operating Voltage | 24 V DC ±10% |
| Static Current | 0.16 A |
| Average No-load Current | 0.62 A |
| Maximum Current | 2.7 A |
| Repeat Positioning Accuracy | ±0.2 mm |
| Opening / Closing Time | 0.2 s |
| Maximum Thumb Fingertip Force | 6.5 N |
| Maximum Four-finger Fingertip Force | 9 N |
| Maximum Five-finger Grip Force | 39 N |
| Thumb Lateral Rotation Range | 0.61 rad (35°) |
| Four-finger Flexion Angle | 1.52 rad (87.2°) |
| Thumb Lateral Swing Speed | 4.92 rad/s (282.4°/s) |
| Four-finger Flexion Speed | 6.343 rad/s (363.6°/s) |
| Thumb Flexion Speed | 7.85 rad/s (450.35°/s) |
| Tactile Sensing | Fingertip tactile sensor array |
A closer look
The connected ecosystem
Build with us
Talk to our team about your application, hardware, or robotics workflow.
Talk to our teamsales@realworldlabs.com